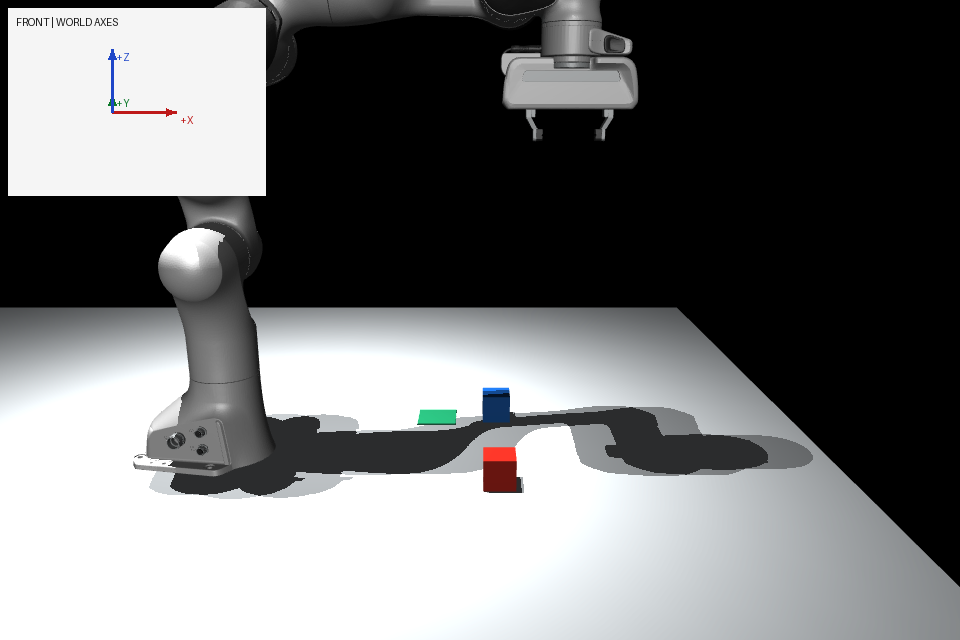
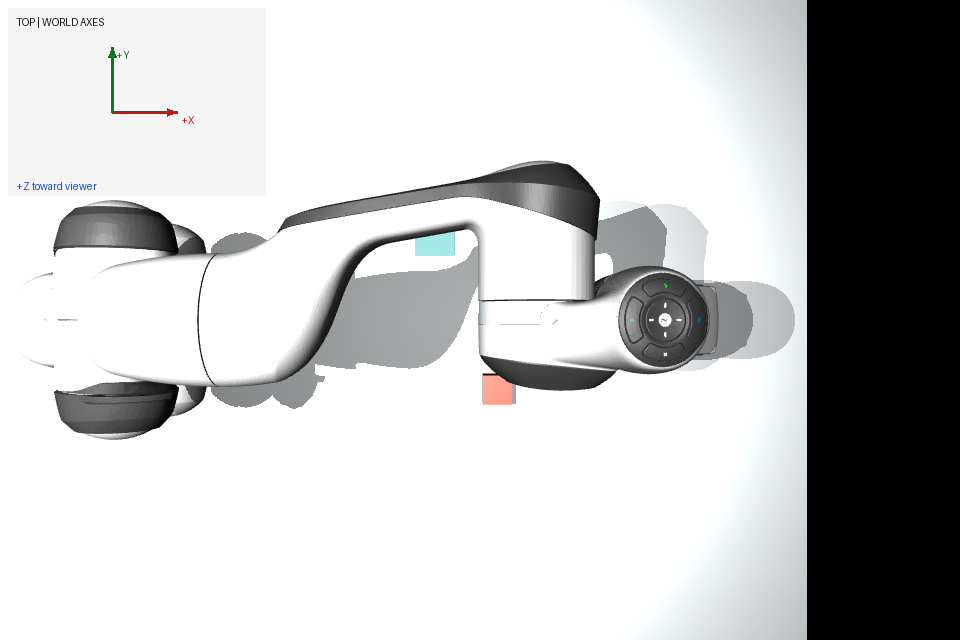
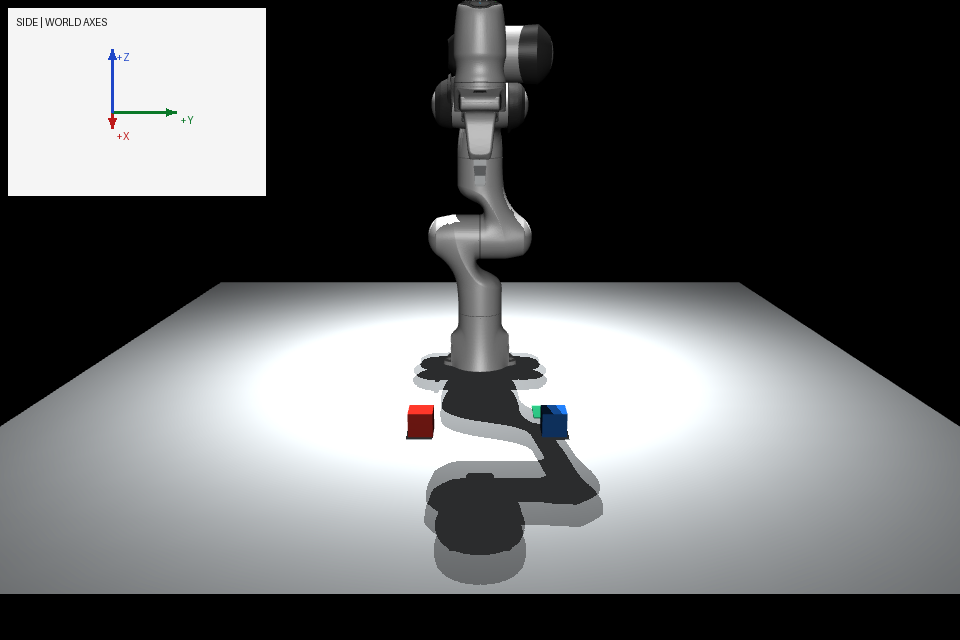
From text-only Jev to visual feedback and physical manipulation.
Goal
Grasp, move and release using visual feedback, without a predefined grasping skill.
Approach
Decisions API · gpt-6-luna
Camera views + scene state → next action.
Current Progress
59 actions: successful placement. Starts within grasping range; stable for 2 seconds after release.
What Still Fails
The gripper still oscillates near the object or releases it too early. Spatial understanding does not consistently translate into correct actions.
Next Experiment: Vision Only
Task + three views → next action. Remove numeric scene metadata and history.